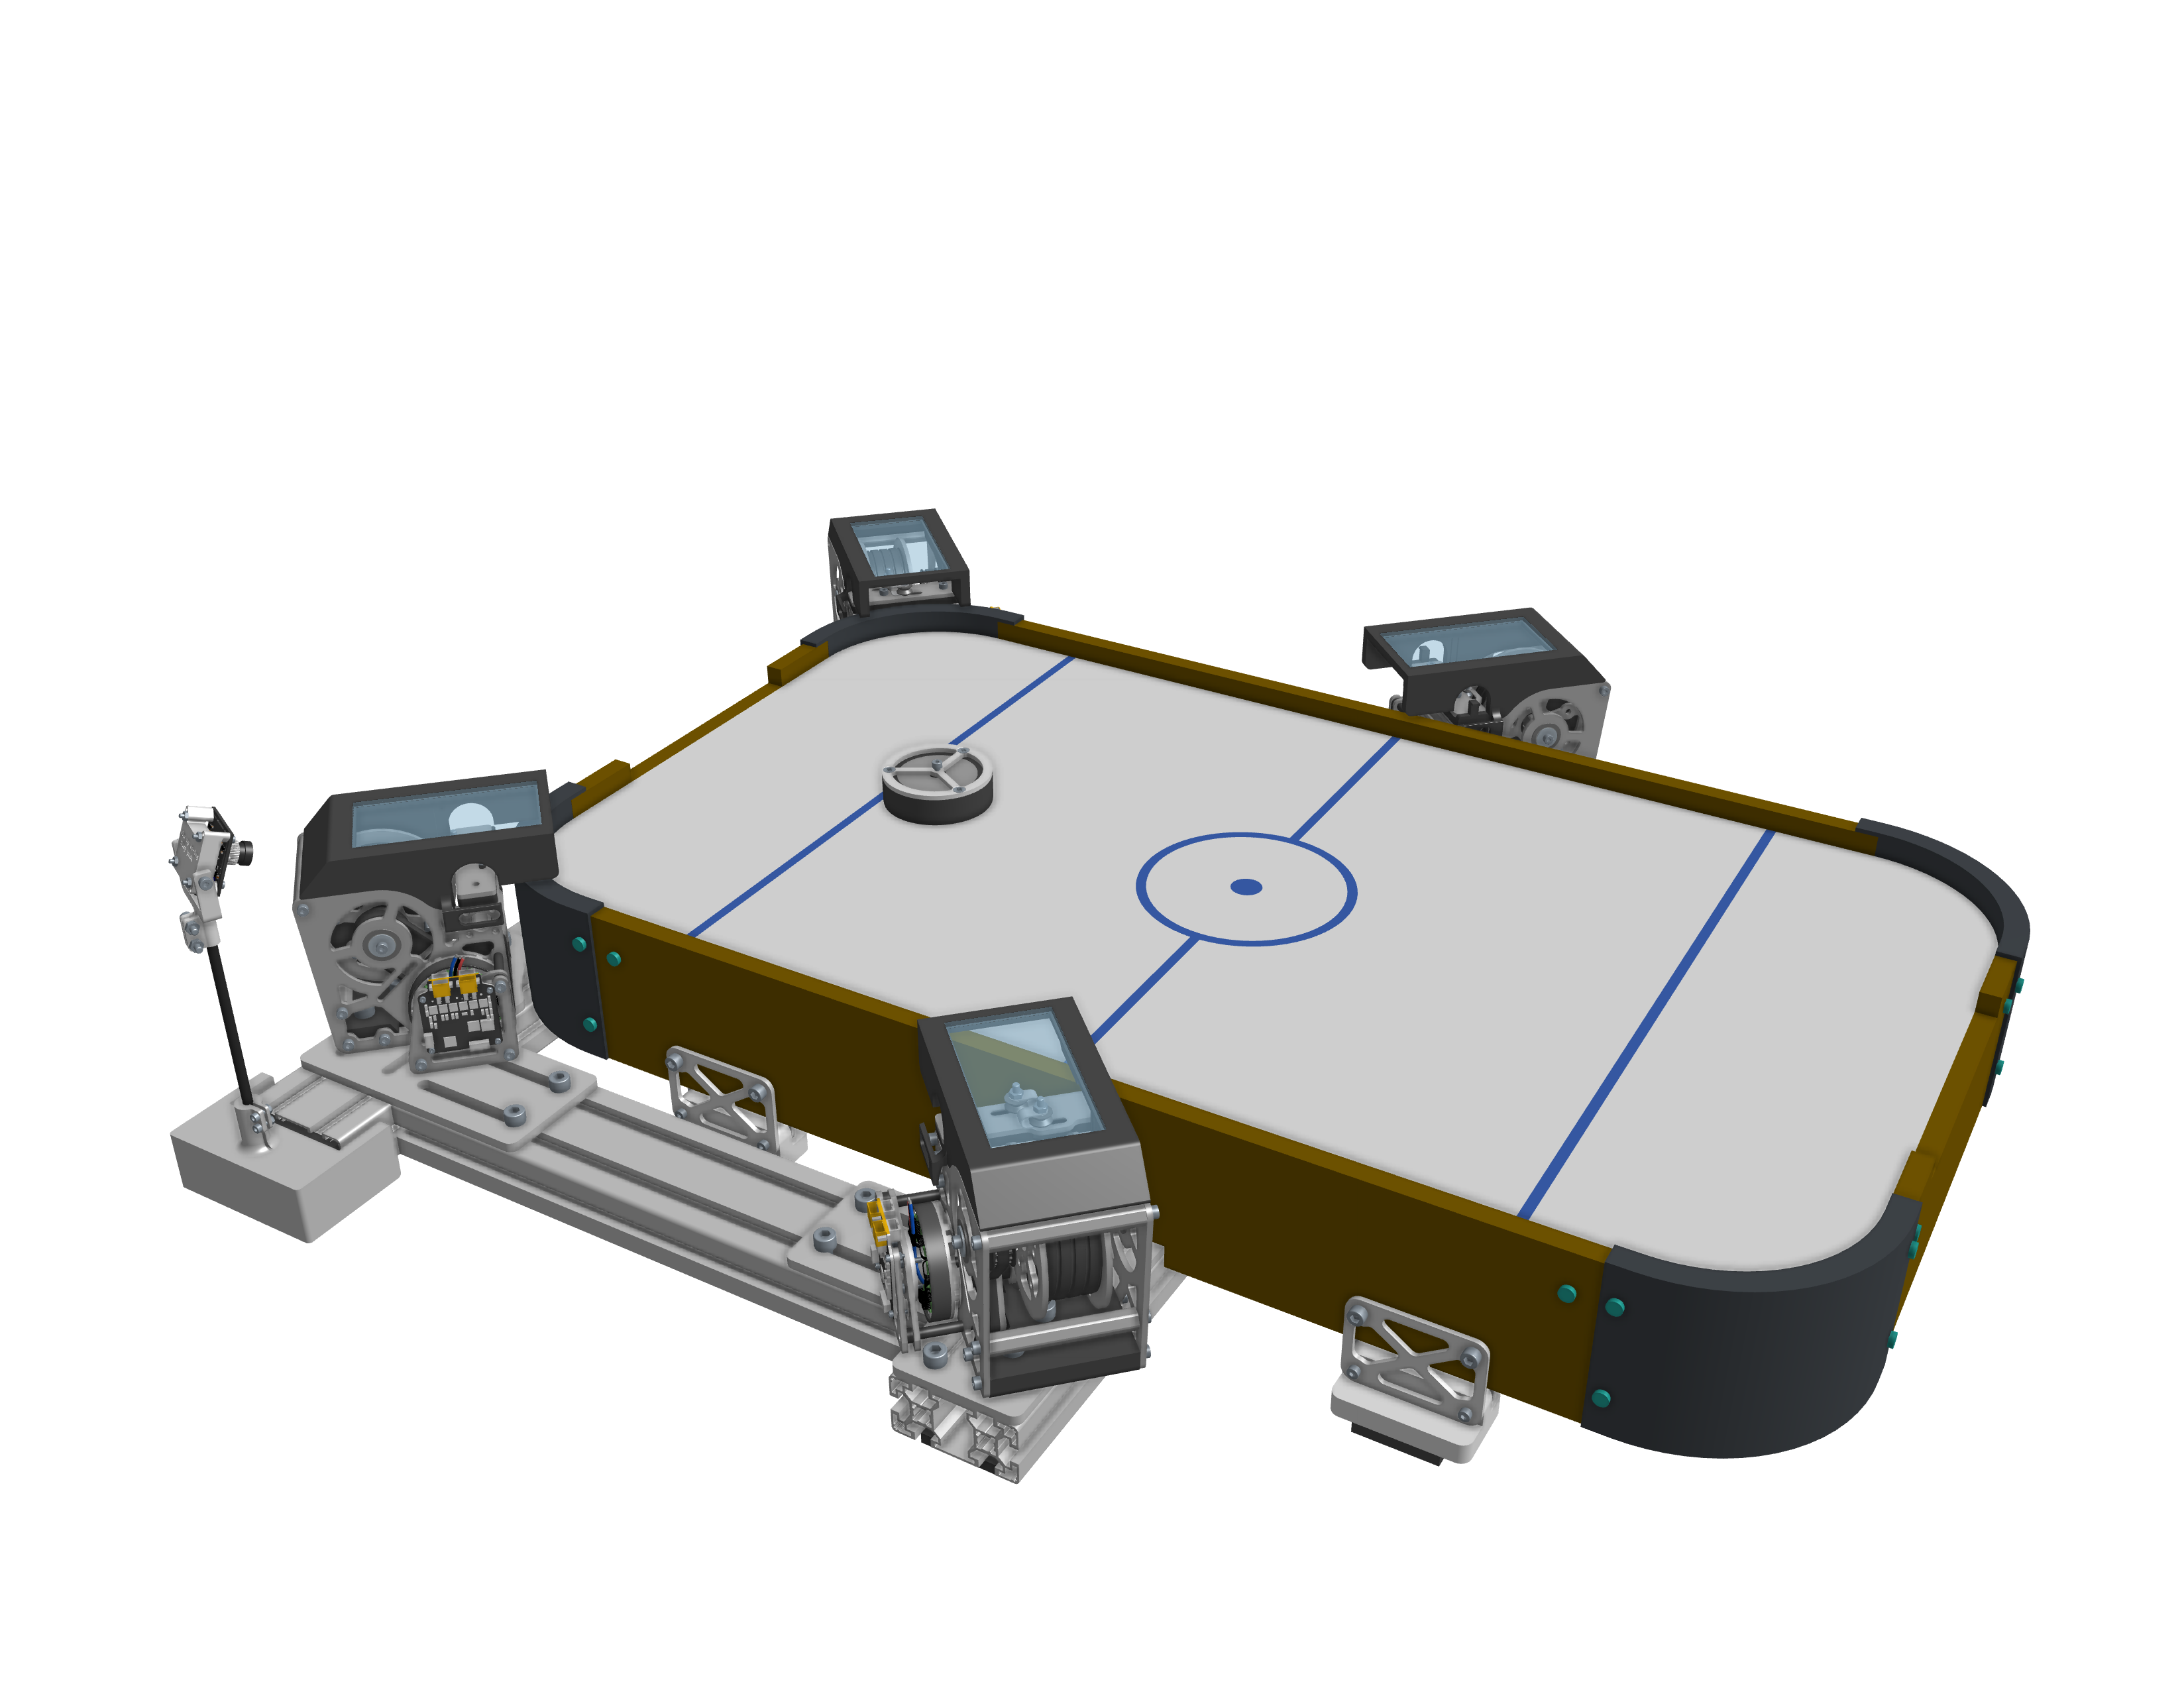
Cable-actuated air hockey robot — full CAD render

Cable-Actuated Air Hockey Robot

A four-cable parallel robot for air hockey. Four corner-mounted MJ5208 BLDC motors tension cables that meet at the mallet; an overhead camera feeds a mallet EKF and a puck predictor; a receding-horizon (naive MPC) planner picks between defending and quintic-spline strikes every 10 ms.

May 2026 · Thomas Yu, Athul Krishnan, Larry Hui, Eric Yamaguchi
ILT

Improvements for Inverse Lithography: Generative RL and Diffusion for ILT

Moving ILT from slow physics-based gradient descent toward conditional latent diffusion and GRPO fine-tuning, with a dual-stage architecture for offline curvilinear mask generation and real-time EUV laser dose compensation.

May 2026 · Larry Hui
Safe Locomotion Project

Constrained RL for Safe Legged Locomotion over Transient Terrain

ME 193B project exploring constrained RL for humanoid locomotion on dynamic stepping stones using IsaacLab and MuJoCo.

November 2025 · Larry Hui, Athul Krishnan, Anuj Kakde