Here you will find some research I have been involved in. I am interested in control theory, robotics, and intelligent mechanical systems, with a focus on uncertainty-aware modeling, safety-critical design, and data-driven methods for dynamical systems. RL and Diffusion models in controls are of interest!
Learning-based methods, control, and optimization for intelligent robotic systems; developing predictive and adaptive models that enable robots to perceive, plan, and act effectively in complex physical environments.
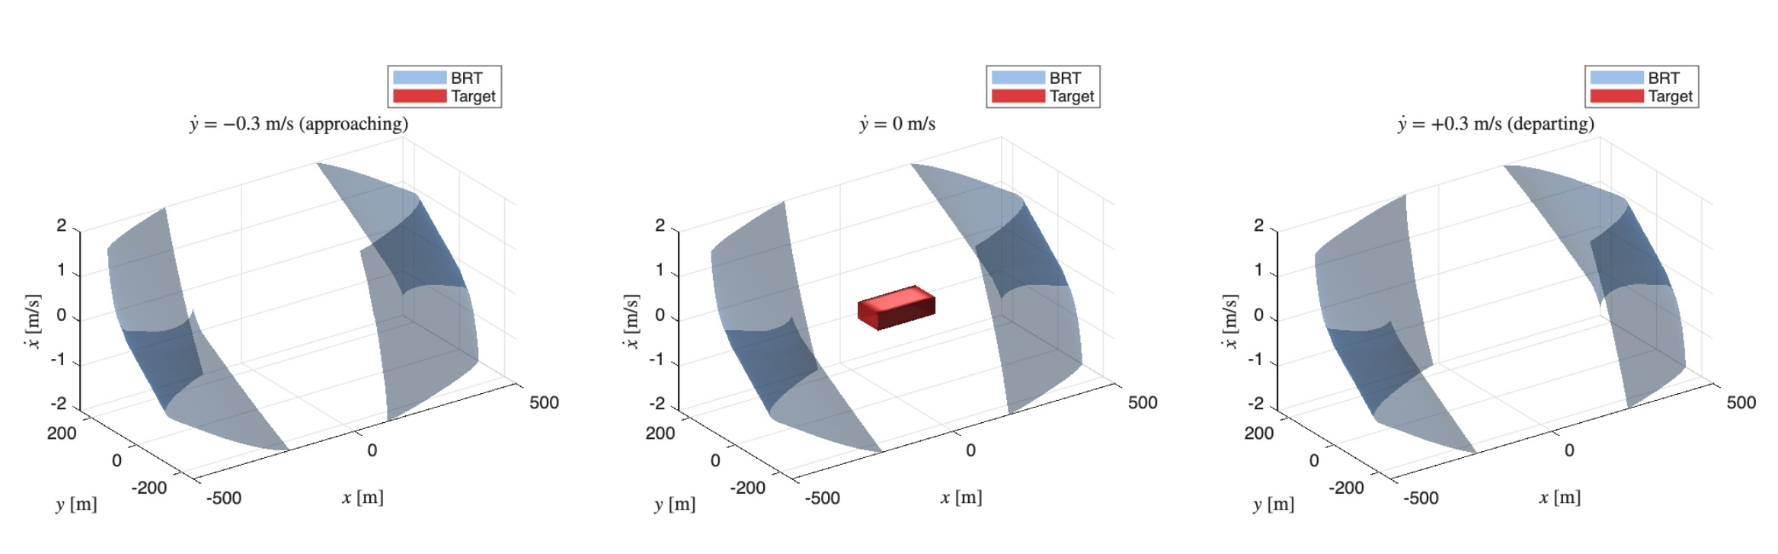
Hamilton-Jacobi Reachability for Spacecraft Collision Avoidance
Accepted to the 20th IEEE International Conference on Control & Automation (ICCA 2026), Almaty, Kazakhstan. We pose two-satellite same-orbit collision avoidance as a zero-sum differential game on planar Hill-Clohessy-Wiltshire dynamics in the RTN frame, compute backward reachable sets via the HJI PDE, and integrate them with a hybrid supervisory automaton governing nominal, evasive, and recovery modes.
Physics-Informed Neural Networks (PINNs) for Fluid-Solid Interactions
Research on implementing Physics-Informed Neural Networks (PINNs) and Mesh Graph Networks (MGNs) for solving fluid-solid interaction problems.
FLOW Lab Research: Fluid Dynamics Exhibit Design
This project details the design, construction, and implementation of an advanced fluid dynamics exhibit featuring adjustable flow rates, force measurement systems, and interactive educational components.